読み取り中…
検索中…
一致する文字列を見つけられません
sensor_covariance_adapter.SensorCovarianceAdapter クラス
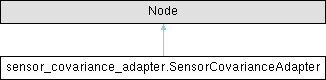
sensor_covariance_adapter.SensorCovarianceAdapter の継承関係図
公開メンバ関数 | |
| __init__ (self) | |
限定公開メンバ関数 | |
| _wheel_callback (self, message) | |
| _imu_callback (self, message) | |
限定公開変数類 | |
| _wheel_linear_variance | |
| _wheel_angular_variance | |
| _imu_yaw_rate_variance | |
| _wheel_pub | |
| _imu_pub | |
| _wheel_callback | |
| _imu_callback | |
詳解
sensor_covariance_adapter.py の 12 行目に定義があります。
構築子と解体子
◆ __init__()
| sensor_covariance_adapter.SensorCovarianceAdapter.__init__ | ( | self | ) |
sensor_covariance_adapter.py の 13 行目に定義があります。
関数詳解
◆ _imu_callback()
|
protected |
sensor_covariance_adapter.py の 48 行目に定義があります。
◆ _wheel_callback()
|
protected |
sensor_covariance_adapter.py の 41 行目に定義があります。
メンバ詳解
◆ _imu_callback
|
protected |
sensor_covariance_adapter.py の 39 行目に定義があります。
◆ _imu_pub
|
protected |
初期値:
= self.create_publisher(
Imu, self.get_parameter('imu_output').value, 10)
sensor_covariance_adapter.py の 32 行目に定義があります。
◆ _imu_yaw_rate_variance
|
protected |
初期値:
= float(
self.get_parameter('imu_yaw_rate_variance').value)
sensor_covariance_adapter.py の 27 行目に定義があります。
◆ _wheel_angular_variance
|
protected |
初期値:
= float(
self.get_parameter('wheel_angular_velocity_variance').value)
sensor_covariance_adapter.py の 25 行目に定義があります。
◆ _wheel_callback
|
protected |
sensor_covariance_adapter.py の 36 行目に定義があります。
◆ _wheel_linear_variance
|
protected |
初期値:
= float(
self.get_parameter('wheel_linear_velocity_variance').value)
sensor_covariance_adapter.py の 23 行目に定義があります。
◆ _wheel_pub
|
protected |
初期値:
= self.create_publisher(
Odometry, self.get_parameter('wheel_odom_output').value, 10)
sensor_covariance_adapter.py の 30 行目に定義があります。
このクラス詳解は次のファイルから抽出されました:
- scripts/sensor_covariance_adapter.py