読み取り中…
検索中…
一致する文字列を見つけられません
trajectory_publisher.TrajectoryPublisher クラス
/odomの位置と向きを、一定の移動距離ごとに記録する。 [詳解]
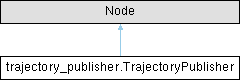
trajectory_publisher.TrajectoryPublisher の継承関係図
公開メンバ関数 | |
| __init__ (self) | |
| odom_callback (self, msg) | |
| calculate_distance (self, pose1, pose2) | |
公開変数類 | |
| frame_id = self.get_parameter('frame_id').value | |
| path_pub = self.create_publisher(Path, '/traveled_path', 10) | |
| odom_sub = self.create_subscription(Odometry, '/odom', self.odom_callback, 10) | |
| path_msg = Path() | |
| last_pose = None | |
| min_distance = self.get_parameter('min_distance').value | |
| max_jump = self.get_parameter('max_jump').value | |
| max_poses = self.get_parameter('max_poses').value | |
詳解
/odomの位置と向きを、一定の移動距離ごとに記録する。
trajectory_publisher.py の 31 行目に定義があります。
構築子と解体子
◆ __init__()
| trajectory_publisher.TrajectoryPublisher.__init__ | ( | self | ) |
trajectory_publisher.py の 34 行目に定義があります。
関数詳解
◆ calculate_distance()
| trajectory_publisher.TrajectoryPublisher.calculate_distance | ( | self, | |
| pose1, | |||
| pose2 ) |
trajectory_publisher.py の 82 行目に定義があります。
◆ odom_callback()
| trajectory_publisher.TrajectoryPublisher.odom_callback | ( | self, | |
| msg ) |
trajectory_publisher.py の 54 行目に定義があります。
メンバ詳解
◆ frame_id
| trajectory_publisher.TrajectoryPublisher.frame_id = self.get_parameter('frame_id').value |
trajectory_publisher.py の 41 行目に定義があります。
◆ last_pose
| trajectory_publisher.TrajectoryPublisher.last_pose = None |
trajectory_publisher.py の 49 行目に定義があります。
◆ max_jump
| trajectory_publisher.TrajectoryPublisher.max_jump = self.get_parameter('max_jump').value |
trajectory_publisher.py の 51 行目に定義があります。
◆ max_poses
| trajectory_publisher.TrajectoryPublisher.max_poses = self.get_parameter('max_poses').value |
trajectory_publisher.py の 52 行目に定義があります。
◆ min_distance
| trajectory_publisher.TrajectoryPublisher.min_distance = self.get_parameter('min_distance').value |
trajectory_publisher.py の 50 行目に定義があります。
◆ odom_sub
| trajectory_publisher.TrajectoryPublisher.odom_sub = self.create_subscription(Odometry, '/odom', self.odom_callback, 10) |
trajectory_publisher.py の 44 行目に定義があります。
◆ path_msg
| trajectory_publisher.TrajectoryPublisher.path_msg = Path() |
trajectory_publisher.py の 46 行目に定義があります。
◆ path_pub
| trajectory_publisher.TrajectoryPublisher.path_pub = self.create_publisher(Path, '/traveled_path', 10) |
trajectory_publisher.py の 43 行目に定義があります。
このクラス詳解は次のファイルから抽出されました:
- scripts/trajectory_publisher.py