読み取り中…
検索中…
一致する文字列を見つけられません
linear_test.OdomLinearTest クラス
目標距離までの残りに応じて速度を調整し、直進走行を試す。 [詳解]
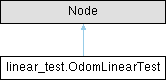
linear_test.OdomLinearTest の継承関係図
公開メンバ関数 | |
| __init__ (self) | |
| odom_callback (self, msg) | |
| control_loop (self) | |
公開変数類 | |
| publisher_ = self.create_publisher(Twist, '/cmd_vel', 10) | |
| subscription | |
| start_x = None | |
| start_y = None | |
| float | current_distance = 0.0 |
| target_distance = TARGET_DISTANCE | |
| bool | is_moving = False |
| timer = self.create_timer(TIMER_PERIOD, self.control_loop) | |
詳解
目標距離までの残りに応じて速度を調整し、直進走行を試す。
linear_test.py の 41 行目に定義があります。
構築子と解体子
◆ __init__()
| linear_test.OdomLinearTest.__init__ | ( | self | ) |
linear_test.py の 44 行目に定義があります。
関数詳解
◆ control_loop()
| linear_test.OdomLinearTest.control_loop | ( | self | ) |
linear_test.py の 81 行目に定義があります。
◆ odom_callback()
| linear_test.OdomLinearTest.odom_callback | ( | self, | |
| msg ) |
linear_test.py の 66 行目に定義があります。
メンバ詳解
◆ current_distance
| float linear_test.OdomLinearTest.current_distance = 0.0 |
linear_test.py の 56 行目に定義があります。
◆ is_moving
| bool linear_test.OdomLinearTest.is_moving = False |
linear_test.py の 58 行目に定義があります。
◆ publisher_
| linear_test.OdomLinearTest.publisher_ = self.create_publisher(Twist, '/cmd_vel', 10) |
linear_test.py の 47 行目に定義があります。
◆ start_x
| linear_test.OdomLinearTest.start_x = None |
linear_test.py の 54 行目に定義があります。
◆ start_y
| linear_test.OdomLinearTest.start_y = None |
linear_test.py の 55 行目に定義があります。
◆ subscription
| linear_test.OdomLinearTest.subscription |
初期値:
= self.create_subscription(
Odometry,
'/odom',
self.odom_callback,
10)
linear_test.py の 48 行目に定義があります。
◆ target_distance
| linear_test.OdomLinearTest.target_distance = TARGET_DISTANCE |
linear_test.py の 57 行目に定義があります。
◆ timer
| linear_test.OdomLinearTest.timer = self.create_timer(TIMER_PERIOD, self.control_loop) |
linear_test.py の 60 行目に定義があります。
このクラス詳解は次のファイルから抽出されました:
- scripts/linear_test.py